Mission systems
TAK
TAK Server and ATAK tracks synchronized through LINK, connecting the TAK mission picture with Lattice through common LINK subjects.
Track synchronization
LINK connects mission systems, platforms, payloads, and sensors through their software interfaces, communications protocols, and message formats. LINK integrations translate those exchanges into a common data and control fabric while preserving each OEM’s protocols and system architecture. Operators use LINK’s common workflow without having to operate a separate OEM screen for each connected system.
Nemesys LINK™ normalizes TAK tracks and Lattice entities into common LINK subjects, enabling permissioned synchronization between the two systems.
TAK Server and ATAK tracks synchronized through LINK, connecting the TAK mission picture with Lattice through common LINK subjects.
Track synchronizationLattice entities synchronized through LINK in Anduril’s sandbox, with permissioned synchronization between Lattice and TAK.
Sandbox connectionLive EO/IR video, gimbal control, telemetry, and sensor footprint context through the Trillium Orion environment.
Gimbal control & videoAircraft tracks from a connected receiver, displayed in the common operating picture.
Aircraft tracksGround vehicle telemetry and driving through connected LINK nodes, bringing vehicle control into the shared mission workflow.
Ground vehicle controlSupported aircraft control, telemetry, and preflight information through the OEM autopilot, which manages flight execution and retains its safety controls.
Aircraft controlWhere platforms expose the interfaces and compute required, LINK works through them. Where additional hardware is needed, the Networked Modular Payload System provides modular compute, mounting, power, data, and payload specific interfaces.
This approach minimizes custom integration while preserving flexibility as platforms and mission requirements evolve.
Discuss platform integrationUse capable onboard resources or add modular compute to suit the host platform.
Connect supported equipment through repeatable integration components, including the DEVCOM CLIK interface.
Address the retention, release, and interface requirements of the selected payload while bringing its status, mission context, and supported command and control functions into LINK’s common operator workflow.
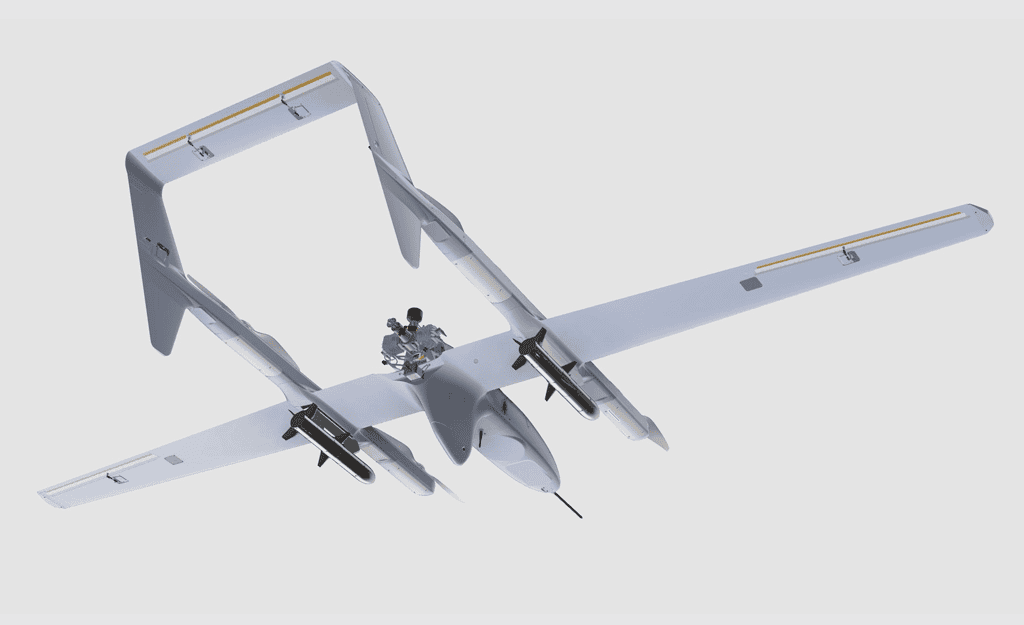
Our integration work spans Group 1, 2, and 3 uncrewed aircraft systems (UAS), as well as unmanned ground vehicles (UGVs). LINK and modular hardware bring payloads into a common workflow without requiring every host vehicle to adopt a fixed architecture.
Mission configurations, payload compatibility, and delivery scope are established with the platform partner and customer.
Bring your platform requirementsScope a demonstration, technical evaluation, or funded integration.